
Interactive demoPreview
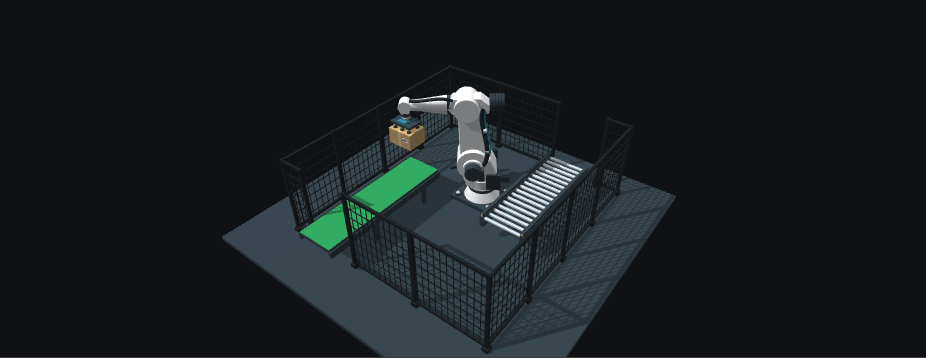
Robot Pick & Place
Pick a box from one infeed belt, place it on one roller outfeed, and return the robot home in an interactive browser simulation.
Try a robot transfer, follow a wrapping cycle and work through practical guides to PLCs, Ignition, IoT and industrial 3D.
Command a robot transfer, follow pallet wrapping or inspect dosing, sealing and cutting in a vertical bagger.
Pick a box from one infeed belt, place it on one roller outfeed, and return the robot home in an interactive browser simulation.
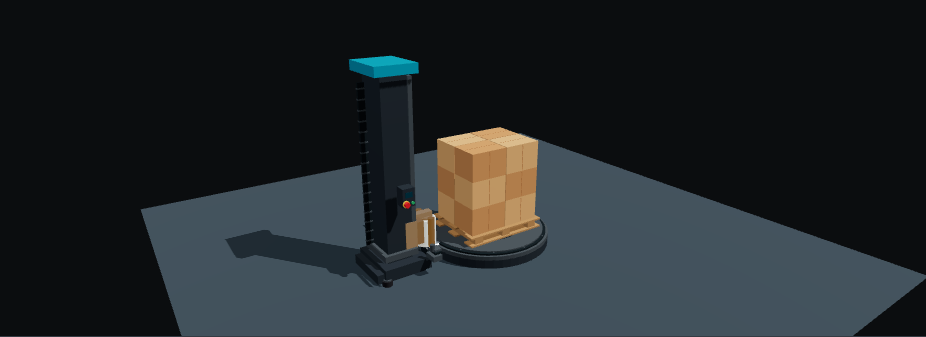
Run a wrapping sequence, inspect the machine components, and follow the film from the roll to the rotating pallet.
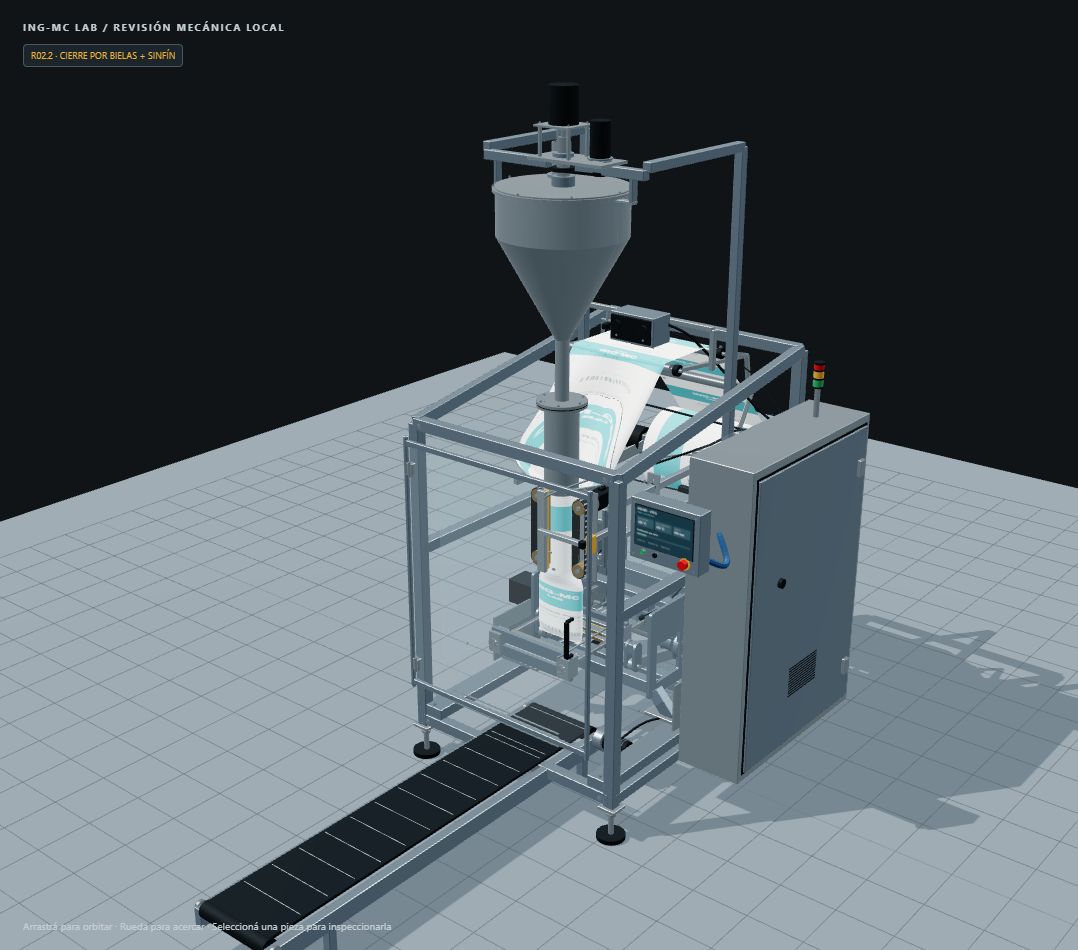
Follow auger dosing, film advance, cross sealing and cutting. Inspect the mechanically coupled jaws and the inside of the hopper.
PLC recovery, Modbus addressing, data quality and gear reduction—with examples you can check and tools you can use.
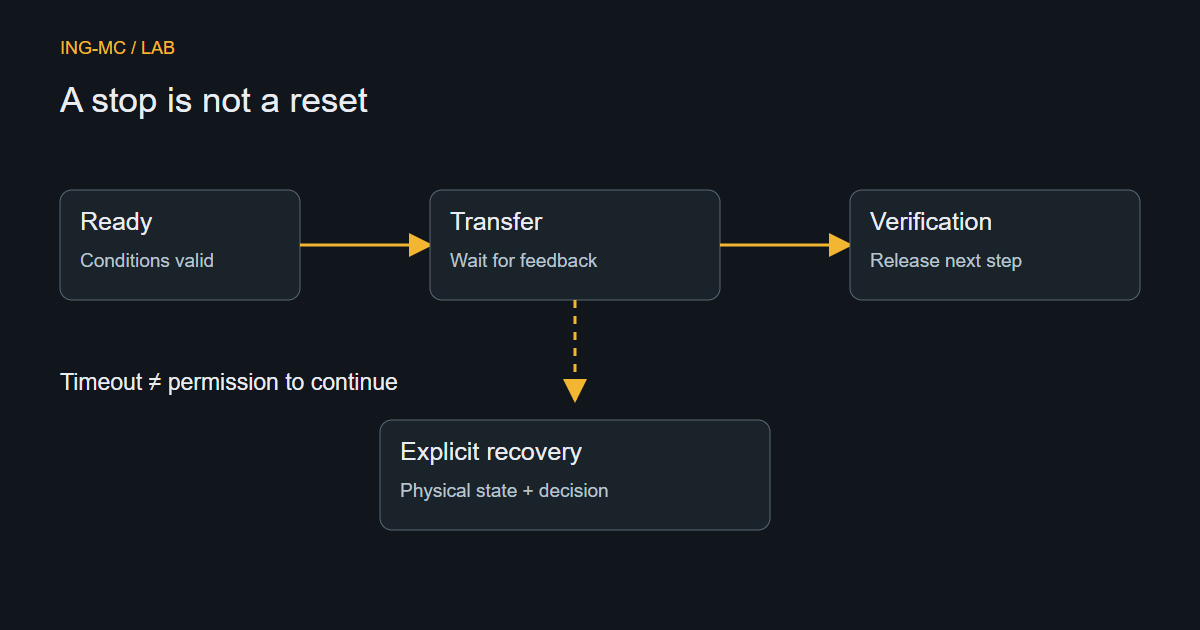
Separate requests, sequence steps and physical feedback so a stopped transfer does not resume from an impossible condition.

Distinguish a manual's register reference from the PDU address, then check function code, scaling and multi-register word order.

Bind resolved values to a visual component without losing their units, quality or age, and test missing-data behavior before using live signals.
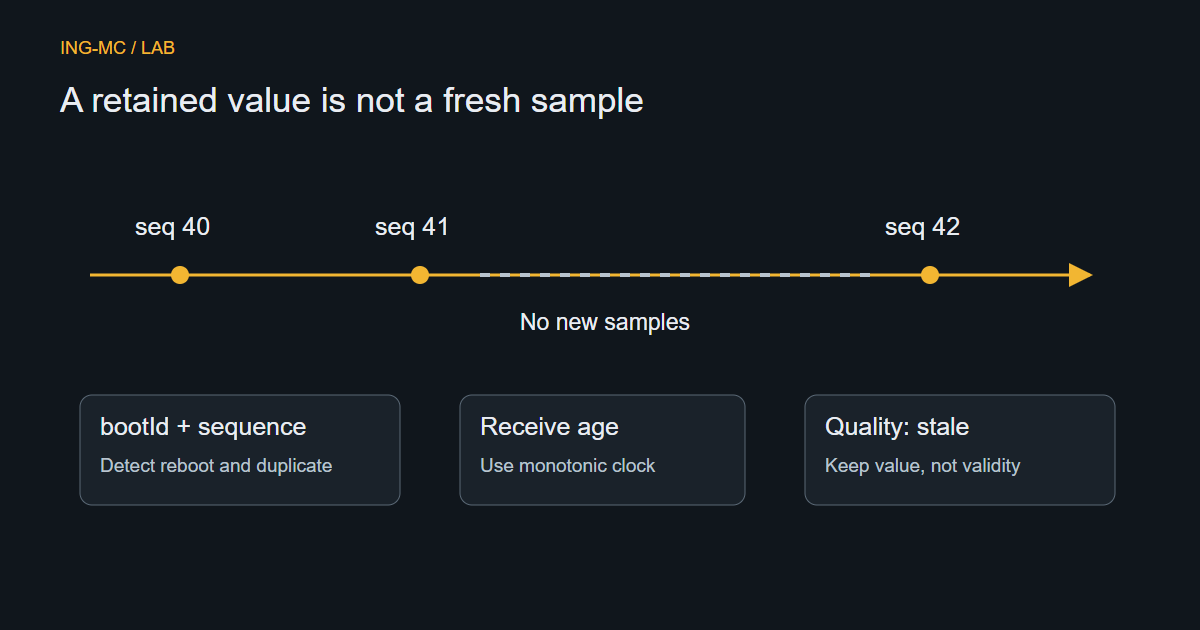
Use session identity, sequence numbers and freshness checks to distinguish a valid sample from a retained value, a retry or a reboot.
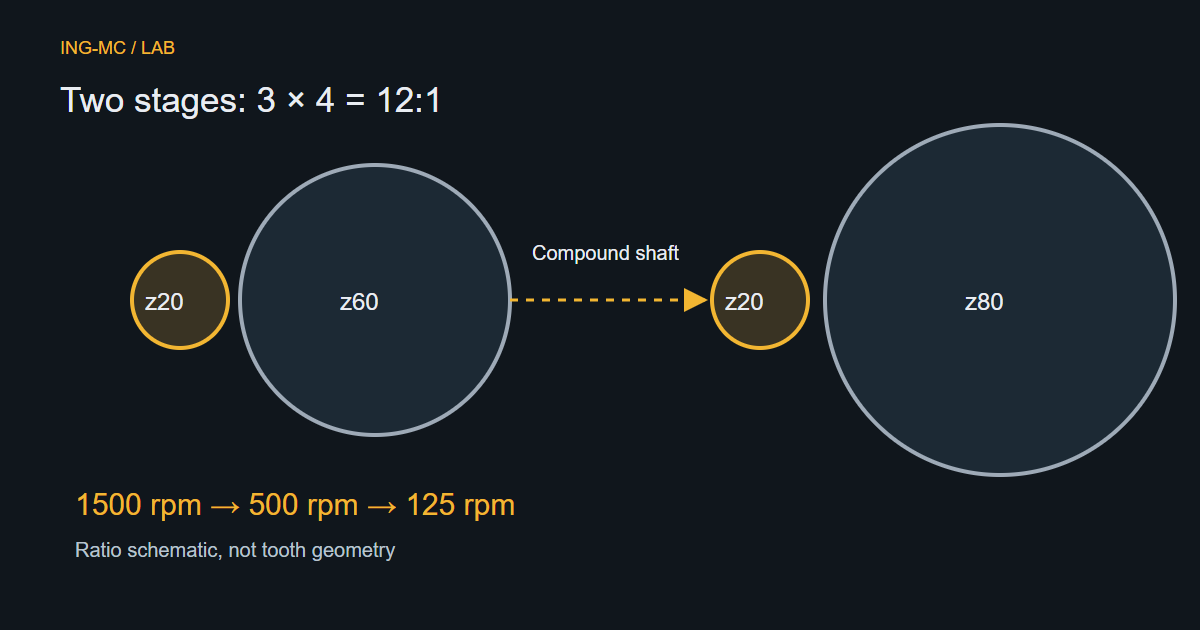
Work through a two-stage reduction, distinguish ideal torque from assumed losses and see why tooth counts alone cannot size a gearbox.
Inspect the R02.2 cross-seal linkage with its actual 75 mm crank, 325 mm rods, jaw travel and motion-closure checks.
A bilingual guide, JSON state observations and a CSV command matrix, generated from the same simulator you can try here.
Get the reference →Robot3D for Perspective, Industrial 3D Studio and a robot-cell interface framework. See each project's scope and availability.
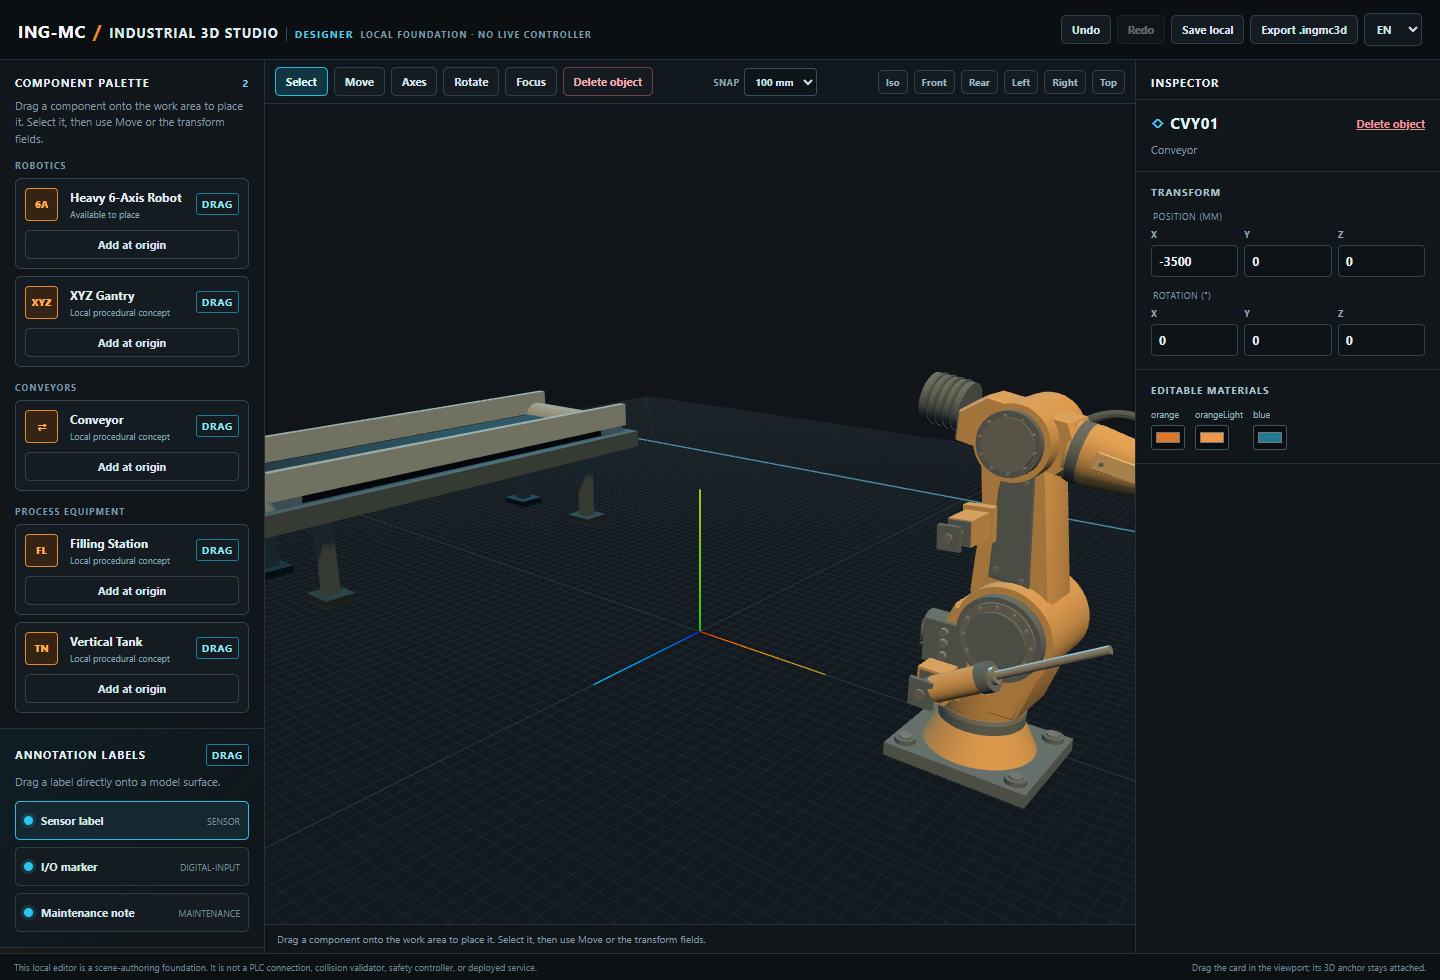
A scene editor in development for arranging industrial assets and exporting .ingmc3d projects.
An Ignition Perspective component in development for industrial robot visualization.
Tell us about the machine, operator workflow and data you need to represent.
